

Science & Tech · Gadgets & EVs · 7 hrs ago
Boston Dynamics tests wheeled Atlas with high-speed moves and a 360-degree jump
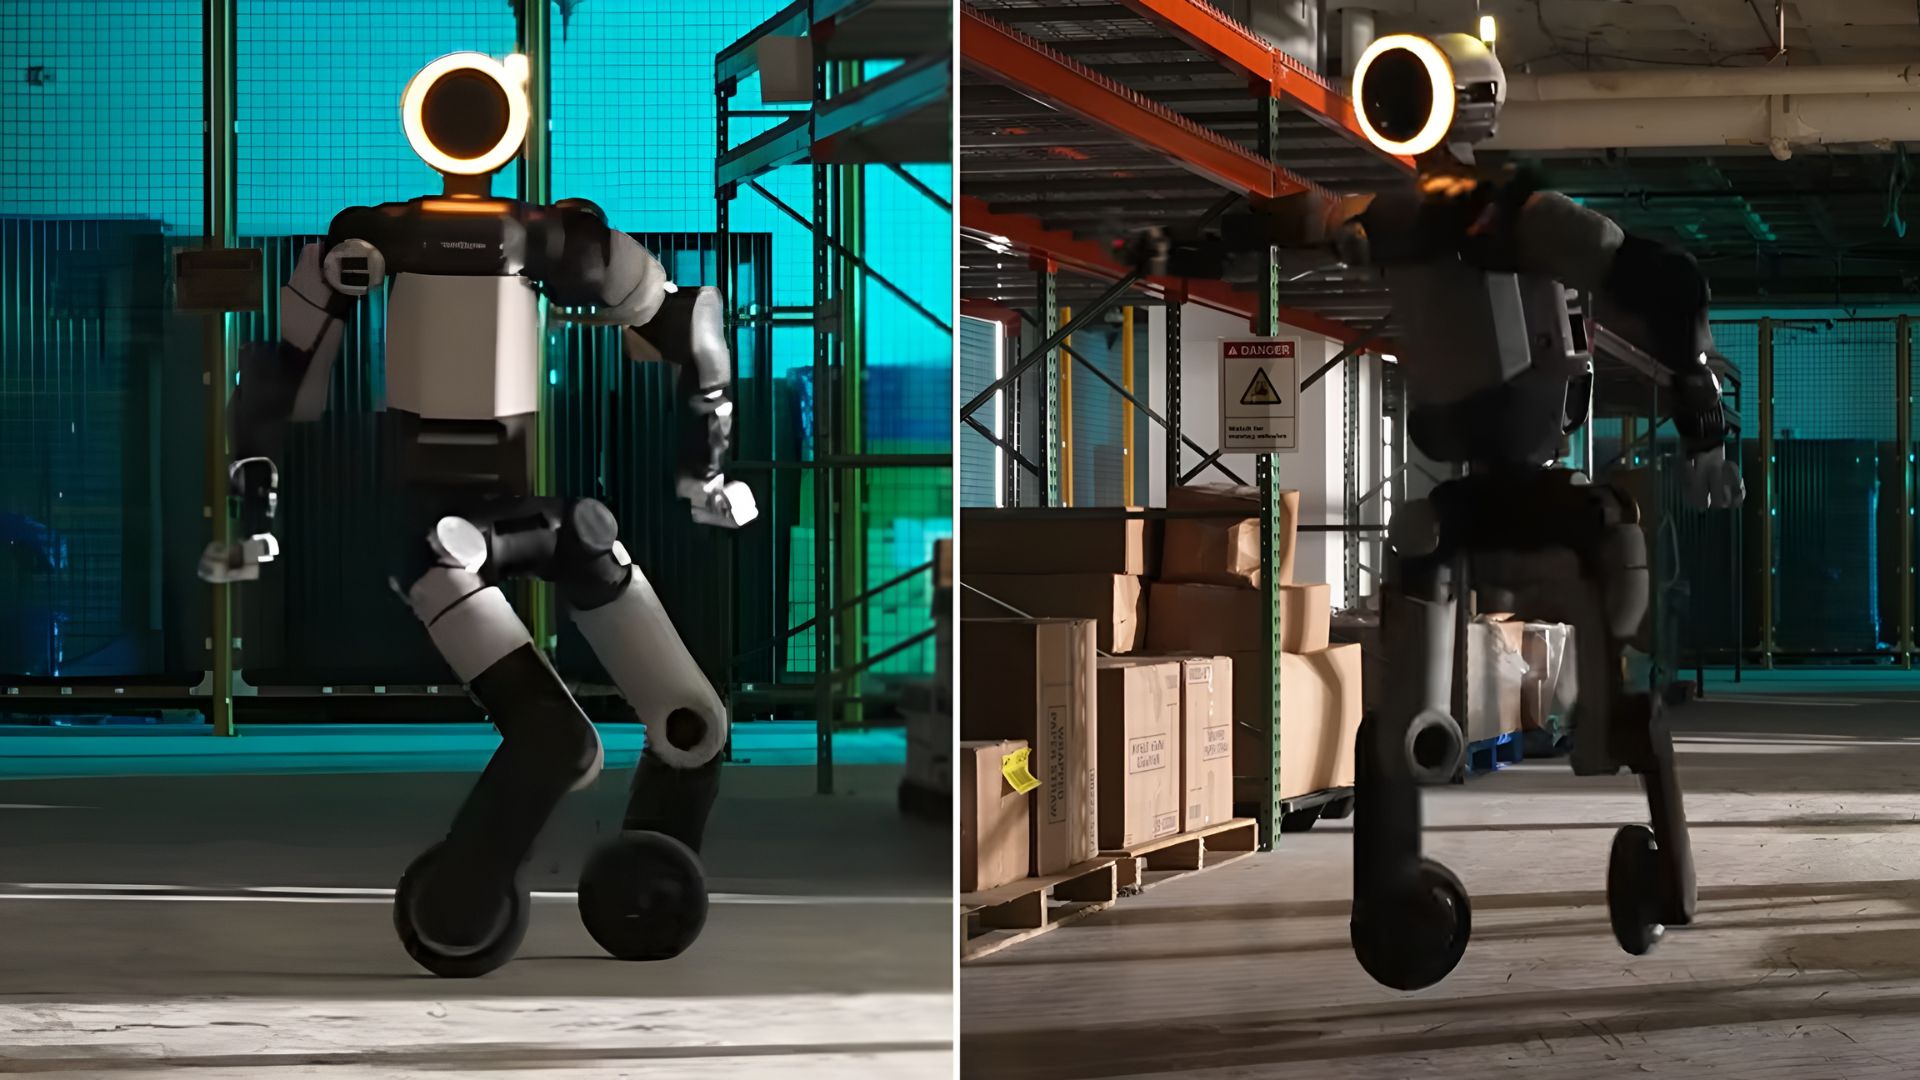
Boston Dynamics fitted its Atlas humanoid robot with scooter wheels to test how it handles fast movement and demanding loads.
The wheels attach to Atlas’ existing ankle actuators through a custom adapter, with no major hardware changes.
The wheeled robot is a research platform, not a planned product, designed to test how well controllers trained in simulation work on real machines.
Simulated motors can behave differently from real ones, so engineers measured Atlas’ actuators and adjusted the simulations to match.
Atlas learned to roll sideways and complete a 360-degree jump, using reinforcement learning and, for the jump, a controller that followed recorded human movement.
The tests help engineers understand how motors and learned controls perform under strain, which could improve reliability and capabilities in Atlas’ standard configuration.

Boston Dynamics tested its Atlas humanoid with electric scooter wheels replacing its feet.
The experimental setup let engineers examine high-speed movement, heavy loads and motor performance.
Atlas performed sideways dashes and a 360-degree jump using reinforcement learning.
Engineers refined simulated motor models to better match the robot’s real hardware.
Boston Dynamics described the wheeled robot as a research platform, not a planned commercial product.
- Who
- Boston Dynamics and its Atlas humanoid robot.
- What
- Engineers tested Atlas with scooter wheels replacing its feet. The robot performed sideways dashes and a 360-degree jump.
- When
- Not stated
- Where
- Not stated
- Why
- To study how simulation-trained controllers work on real hardware and test the robot’s motors under demanding conditions.
This story does not have two clearly opposing sides.
This story does not have a timeline yet.
- Wheel conversion
- Standard electric scooter wheels attached with one custom adapter
- Sideways movement
- Atlas learned to steer its wheels and roll sideways
- Jump
- 360-degree jump using a trajectory-tracking controller
- Training method
- Reinforcement learning
- Project purpose
- Research platform, not a planned commercial product